Current work
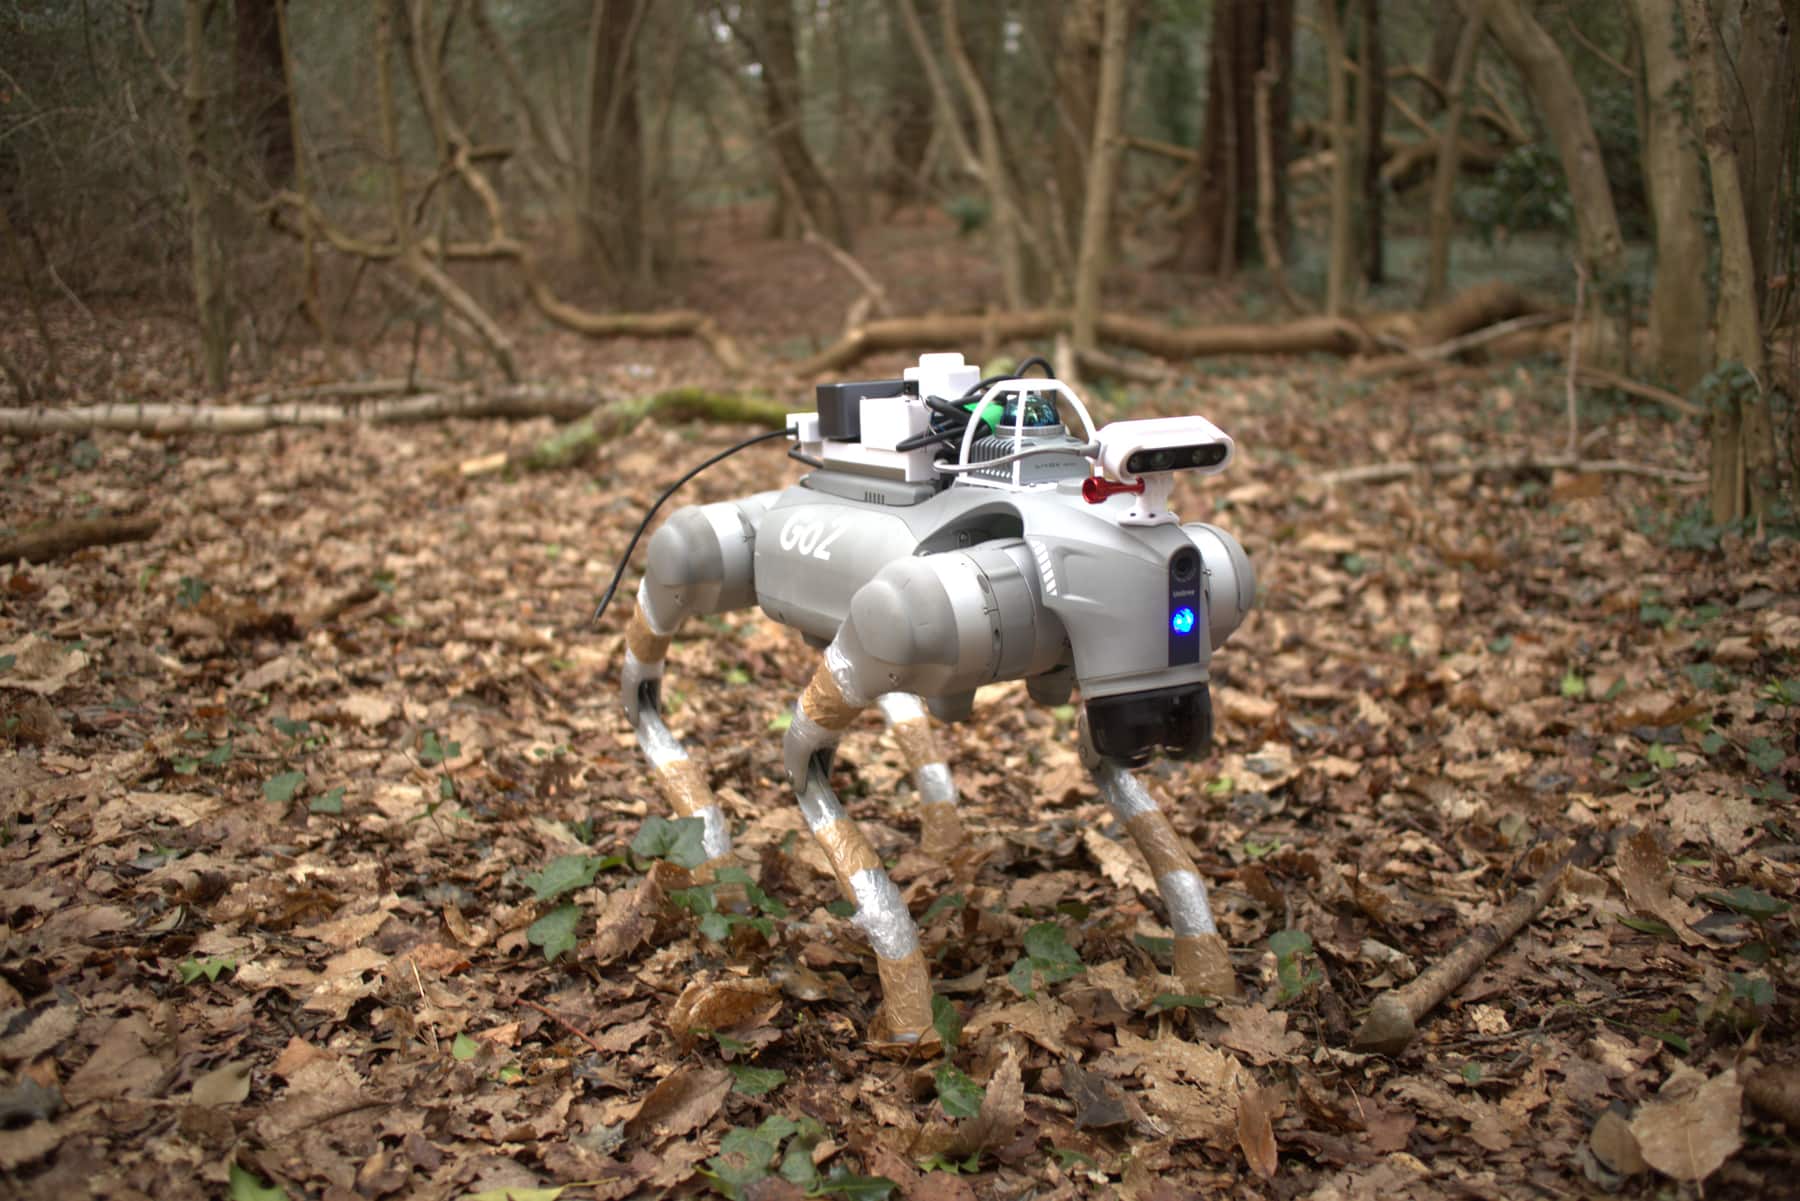
- Scalable robotic monitoring of forest environments
- Resource-Efficient Collective Decision Making in Robot Swarms
- Incremental learning on resource-constrained embedded systems
- User-aware adaptive human-robot interaction
- Resilient forest autonomy
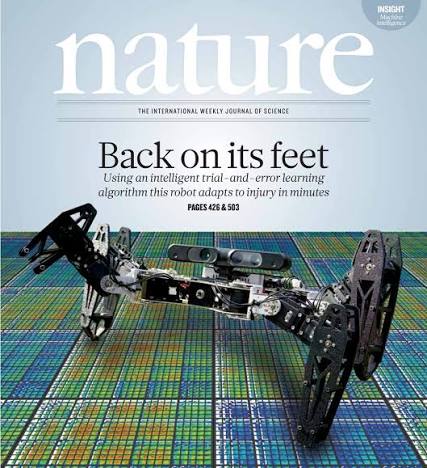
Nature cover